
Robot lithium Battery Pack
Quick answer: Robot battery packs are specified on four axes: energy (Wh for the required runtime), peak power (C-rate for motor bursts), form factor (the mechanical envelope the robot can spare) and communication (CAN, RS485 or SMBus to the robot’s firmware). Most mobile robots use NMC where compactness matters and LiFePO4 where cycle life and safety dominate. CMX Battery designs custom packs to your envelope, connector and protocol.
What battery do robots actually use?
Almost every modern mobile robot runs on lithium-ion. The question is not whether to use lithium but which lithium, and that is decided by whichever of four constraints binds first: energy, power, shape, or cost. Choosing on energy density alone is the most common specification error — it produces a pack that fits, lasts the stated runtime, and then shuts the robot down the first time all motors start together.
| Chemistry | Energy density | Cycle life | Best for | Trade-off |
|---|---|---|---|---|
| NMC (Li-ion) | High — 200–260Wh/kg | 800–1,500 | Service robots, drones, humanoids, compact AMRs | Lower thermal margin than LFP |
| LiFePO4 (LFP) | Moderate — 120–160Wh/kg | 2,000–5,000 | AGVs, AMRs, industrial platforms, fleets | Larger and heavier for the same Wh |
| Lithium polymer | High, and shapeable | 500–1,000 | Thin, curved or irregular enclosures | Lower cycle life, more swelling risk if poorly constrained |
| LTO | Low — 70–90Wh/kg | 10,000+ | Extreme fast-charge or extreme-temperature duty | Expensive and bulky |
The four axes of a robot battery specification
- Energy. Average system power (W) x required runtime (h) = watt-hours. Divide by system voltage for amp-hours. Add 20–30% margin for capacity fade across the warranty period — a pack that is exactly right on day one is undersized in year three.
- Peak power. The pack’s continuous and peak discharge rating must exceed the worst case: all motors starting together, or a winch or lift stalling. This is where most packs fail, not on capacity.
- Form factor. The mechanical envelope the robot can spare, plus mounting points, connector position and pin-out. Lock this before cell selection.
- Communication. CAN, RS485, SMBus or UART, and what the robot expects to read: state of charge, state of health, cell voltages, temperature and fault flags.
How to specify a custom robot battery pack
- Define the duty cycle in power and time. Measure or estimate average system power and peak power separately, plus the required runtime and the available charge window. Average power x runtime gives energy; peak power sets the C-rate.
- Choose chemistry from the constraint that binds. If volume and mass are tight, NMC. If cycle life, safety and cost bind, LiFePO4. If the enclosure is thin or irregular, lithium polymer. Do not pick on energy density alone.
- Fix the mechanical envelope and connector early. Battery geometry drives everything else. Lock the envelope, mounting points, connector and pin-out before cell selection, otherwise the pack redesigns itself twice.
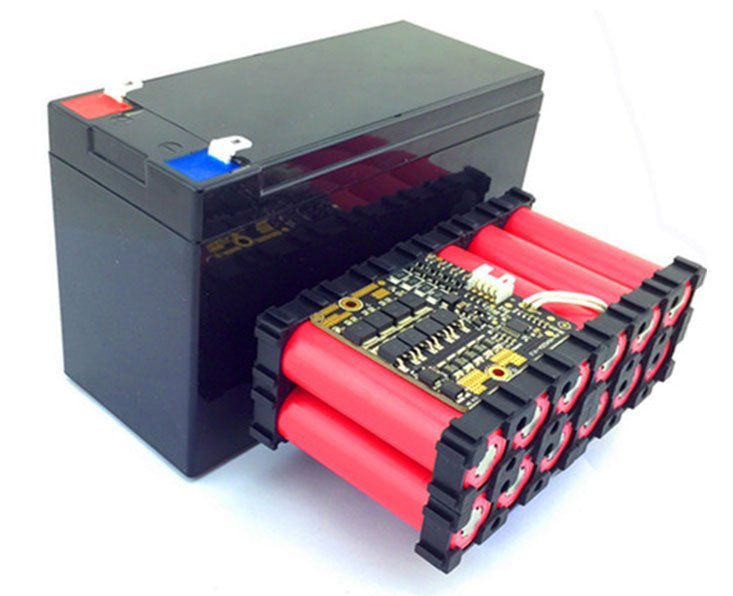
- Specify the BMS and communication protocol. Choose the protection thresholds, the balancing strategy and the bus (CAN, RS485, SMBus, UART). This is the interface between the pack and the robot’s firmware, so define it with the firmware team, not after.
- Plan thermal behaviour and certification together. Fast charging and high peak current create heat. Decide the allowable cell temperature rise, then choose the enclosure and the certification path (UN38.3 plus IEC 62133 / UL) before tooling.
Battery choice by robot type
| Robot type | Typical voltage | Chemistry | What matters most |
|---|---|---|---|
| AGV / AMR (warehouse) | 24V / 48V | LiFePO4 | Cycle life, opportunity charging, CAN telemetry |
| Robot vacuum / floor cleaner | 14.4V / 25.6V | NMC or LFP | Cost, pack height, docking charge |
| Delivery robot | 24V / 48V | NMC | Energy density, weather sealing |
| Service / hospitality robot | 24V | NMC or LFP | Runtime per shift, quiet charging |
| Inspection / survey drone | 22.2V / 44.4V | NMC (high C-rate) | Discharge rate, weight |
| Humanoid / legged robot | 48V+ | NMC | Peak burst current, energy density |
| Medical / lab robot | 24V | LiFePO4 | Safety, reliability, documentation |
BMS and communication: the interface your firmware team cares about
In a robot, the battery is not a dumb source — it is a peripheral. The BMS is what lets the robot estimate remaining runtime accurately, schedule a return to dock, log cell health over the fleet, and shut down safely rather than abruptly.
| Bus | Typical use | What it carries |
|---|---|---|
| CAN bus | Industrial AGVs, AMRs, larger platforms | SoC, SoH, cell voltages, temperatures, fault codes |
| RS485 | Industrial equipment, chargers | Similar to CAN over longer distances |
| SMBus / I2C | Consumer and small robots | Fuel-gauge data to the main controller |
| UART / TTL | Low-cost and hobby platforms | Basic voltage, current and SoC |
Charging and docking strategies
- Contact docking. The robot drives onto pads; the pack charges at up to 1C between tasks. Simplest and most efficient.
- Inductive / wireless. No exposed contacts, which matters outdoors or in wet environments. Slightly lower efficiency and more thermal management.
- Opportunity charging. Short top-ups during idle time keep the robot in a mid-state-of-charge band, which measurably extends cycle life.
- Battery swap. Used where downtime is unaffordable; requires a hot-swap design with its own safety interlocks.
Custom pack design at CMX Battery
We build robot packs to your envelope rather than asking you to design around a catalogue part. Send the mechanical drawing, connector and electrical specification and we handle cell selection, BMS configuration, enclosure design, prototyping and certification. See custom battery pack design for the process, or the 18650 pack calculator for a first-pass estimate.
Certifications and transport
- UN38.3 — mandatory lithium transport test; required for any shipment.
- IEC 62133 — the common safety standard for portable and semi-portable lithium applications, and the usual baseline for robots.
- UL 2054 / UL 2271 — North American equivalents for battery packs and light electric vehicle batteries.
- IEC 62619 — for industrial equipment and stationary-adjacent applications.
- CE / RoHS — EU conformity and hazardous-substance restriction.
Robot battery FAQ
What battery chemistry is best for a robot?
Most mobile robots use lithium-ion: NMC where energy density and compactness matter most (service robots, drones, humanoids), and LiFePO4 where cycle life, safety and cost dominate (AGVs, AMRs, industrial platforms). Lithium polymer suits thin or unusually shaped enclosures.
How do I size a robot battery?
Work from energy, not from amp-hours. Multiply the robot’s average system power by the required runtime in hours to get watt-hours, divide by system voltage for amp-hours, then add 20–30% margin for peak current and for capacity fade over the warranty period.
Why does my robot shut down under acceleration?
Because the pack’s continuous discharge rating is below the motor’s peak current. Robots draw short, high-current bursts that a pack sized on average current cannot supply. Specify the peak C-rate as well as the capacity.
Do I need CAN or SMBus communication?
For anything with a charging dock, fleet management or a safety case, yes. CAN or RS485 suits industrial AGVs; SMBus or a simple fuel-gauge IC suits smaller consumer robots. Communication also lets the robot report state of health rather than only state of charge.
Can you match an existing battery form factor?
Yes. Custom pack design is our core business — send the mechanical envelope, connector and electrical specification and we will design to it, including the mounting features and the connector pin-out.
What is the typical lead time for a custom robot pack?
Prototype samples typically ship in three to five weeks after design freeze, with production volumes following once samples are approved. Exact timing depends on cell availability and certification scope.
What certifications apply to robot batteries?
UN38.3 for transport is universal. IEC 62133 is the common safety standard for portable and semi-portable applications; UL 2054 or UL 2271 apply in North America; IEC 62619 covers industrial equipment. Robots shipping to the EU also need CE, and the end product may need EMC and machinery-directive assessment.
Can the battery charge while the robot is working?
Yes — that is what makes continuous-duty AMRs viable. It needs a charge strategy the BMS accepts (opportunity or contact/inductive docking) and thermal headroom, because continuous fast charging generates heat the enclosure has to shed.
Build your robot pack with CMX Battery
Robot packs are engineered to order rather than bought off a shelf. Start from the route that matches where you are: a first-pass sizing estimate, a full custom design programme, or a private-label route if you are shipping under your own brand.
Design routes
- 18650 pack calculator — first-pass sizing
- Custom battery pack design
- OEM / ODM process
- Private label LiFePO4
- LiFePO4 cells and modules
More in this series
Explore related solutions
- Residential Energy Storage
- Whole Home Battery Backup
- Off-Grid Solar Systems
- C&I Energy Storage
- Peak Shaving Systems
- UPS Battery Solutions
- Telecom & UPS Backup
- Forklift Lithium Batteries
- RV Lithium Batteries
- Marine LiFePO4 Batteries
- Golf Cart Lithium Batteries
- Military Battery Packs
- All Solutions
Request a robot battery quote
Send us your mechanical envelope, voltage, average and peak power, runtime target and communication protocol — we return a pack concept within three working days.